PROJECT ARCHIVE
Projects
Industry and graduate projects. Select a project for details, source code, and available demos.
25 projects
 ByteDance
2021–2024 · 7 projects
PICO MR Cloud-Based Mapping & Localization (VPS)
PICO MR cloud-based mapping and localization — Visual Positioning Service (VPS).
High-Performance Bundle Adjustment for Large-Scale Scenes
High-performance Bundle Adjustment for large-scale scenes — Ceres CUDA, FastBA, MegBA.
Multi-Device Anchor Map Sharing
Real-time sharing and localization of anchor maps across multiple devices, enabling multi-player MR games.
MR Spatial Anchor on PICO Headset
Vision-based, low-cost mapping and localization powering MR Spatial Anchors on PICO headsets.
Line-Feature based VIO for Re-Localization
Line-feature based VIO designed to improve re-localization performance on MR headsets.
Cloud-Loc + Local 6DoF Tracking Fusion
Fuse cloud-based high-precision localization results into the on-device 6DoF tracking loop.
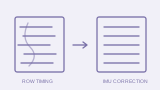
Rolling Shutter Compensation with IMU
Use IMU data to compensate for the rolling-shutter "jelly" effect in RGB cameras under fast motion.
 MEGVII
2019–2021 · 4 projects
Multi-Camera & Lidar Extrinsic Calibration
Multi-camera and lidar extrinsic calibration with a re-engineered workflow.
OCR Toolbox (Detection + Recognition + TensorRT)
End-to-end OCR toolbox covering detection, recognition, post-processing, and TensorRT acceleration.
Parking Space Semantic Mapping
Camera-based semantic mapping for parking environments using line and marker features.
AGV Multi-Sensor Fusion
AGV-level multi-sensor fusion module for static and dynamic obstacle state estimation.
 Horizon Robotics
2018–2019 · 3 projects
Perception Model Evaluation Toolboxes
Evaluation toolboxes covering classification, keypoint detection, keypoint regression, and image-based 3D-box tasks.
Vehicle / Cyclist 3D-Box Detection
Vehicle and cyclist 3D bounding box detection for the auto-driving perception stack.
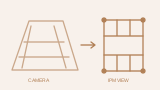
IPM-based Parking Space Detection
Camera IPM-based parking space detection that emits 3D coordinates for downstream parking planning.
 University of Pennsylvania
2016–2018 · 11 projects
EKF-Based Visual Inertial Odometry
Implemented visual-inertial odometry for quadrotor pose and velocity estimation, with ROS simulation and real-flight tests.
Planning and Optimization
Implemented polynomial trajectory generation for quadrotors and camera calibration using reprojection-error optimization.
3D Object Detection and Recognition
Built a network for 3D-MNIST classification, 3D bounding box estimation, and depth estimation.
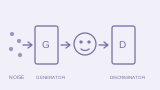
Generative Models Implementation
Implemented autoencoders, VAEs, and GAN variants, including image-to-image translation models.
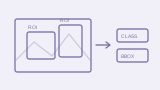
Faster RCNN Playing with Cifar10 and Cifar100
Implemented Faster R-CNN with TensorFlow for object detection and classification using CIFAR datasets.
SFM and Visual SLAM
Implemented Structure from Motion, visual odometry, and bundle adjustment for quadrotor mapping.
Machine Learning applied in the modern robot
Implemented object detection with GMMs, gesture recognition with HMMs, and reinforcement learning methods.
The Particle Filter based Fast SLAM
Implemented particle-filter SLAM using IMU prediction and laser-scan updates.
Orientation Estimation using Unscented Kalman Filter(UKF)
Implemented an Unscented Kalman Filter for orientation estimation using IMU data.
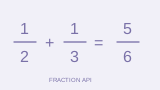
Fraction API Design
Implemented a Java API for fraction arithmetic.
The Face Detection and Replacement Package Design
Built face detection and replacement using color-based segmentation, PCA, and Face++.
No projects match your search.